Image Feature
Overview
eyJ2ZXJzaW9uIjoiMSIsImVuY29kaW5nIjoiYnN0cmluZyIsImNvbXByZXNzZWQiOnRydWUsImVuY29kZWQiOiJ4nOWb22/b1lx1MDAxZMff81dcdTAwMTjua82e+/mdvvmm1JfISezUdochoCRKokWRskRZkotcdTAwMDAtiqYttqHZyzAsQ4v2qX1cdTAwMTmwXHUwMDFisHbd/prZTv6L/ShfSMmWQyemJCAxIEDnUPydy/dzflx1MDAxNzJcdTAwMWbfmZmZXHJ7XHJn9v2ZWadbtD231LQ7s+9G7Vx1MDAwN06z5Vx1MDAwNj52sf73VtBuXHUwMDE2+1dWw7DRev+99+xGw6q4YSFcYmpWMaif/szxnLrjhy288Ff4fWbm4/5nwlDodMP+tf3W2IxcdTAwMTTDjfnA71tcdTAwMDQuhTaaxlx1MDAxN7itJTRcdTAwMTQ6Jewt217LiXuiptl8ob5cdTAwMTnU5735OZanbO+wntvbYbHRsut5m2HP64+nXHUwMDE14LTjvlbYXGZqzrZbXG6r53NPtI/6VTNoV6q+04rmTS9ag4ZddMNe1EbIRavtV/r3iFu6+E1cdTAwMTiwmOSKUKJcdTAwMDWjoOVFd3RcdTAwMDNGlVx1MDAwNYxTRijVXHUwMDAzvadcdTAwMDNbXGa8oFx1MDAxOVxy7Fx1MDAxZOpEf/HQXG52sVbB8fmli2vCpu23XHUwMDFhdlx1MDAxMzcqvq5zNmVcdTAwMDFcdTAwMTZcdTAwMThjXHUwMDA0nNkyXHUwMDE3V1RcdTAwMWS3Ulxyo8EkrDv9TaBMMUaNSGxiZLOxUuor4dfx0jfturNcdTAwMTL9xG97XnL9/NLZ+lxydFx1MDAxNKKO5YSo4lu1XHUwMDFiJftUXHUwMDAyVDNcdTAwMDFCcKWFiIfmuX5t+HZeUKxdoZpy4Ieb7mG0K4xcZrTm7Lrr9Vx1MDAwNna1L2BcXMXT5Vx1MDAxY2ie99xKpOVZzylcdTAwMGaKPHRcdTAwMTGvi+4waMS9RTRju77TvLwsQdOtuL7tbV1tXHUwMDEyZ+h8cL4p1EpsS8FuOVFv1Fx1MDAwZf3GJ+/eXGZHJYdcdTAwMWLPceRGa6WNgdQ49vZcdTAwMGW8sENcdTAwMWYuLPfapLi74e947HC6cVSKWSgppaRkmlx1MDAwYlx1MDAxZU/2lEZpUW2E5qCVkYhlZjhcdTAwMDKxhDSGSqoo5Vxm4ulcXIOjXCJcdTAwMTKii+NhjZ9GXHUwMDAxXHUwMDFhmElqNVNcdTAwMWEjRNpNZ7w8XjKaJZFcdTAwMTTMcOs5klx1MDAxND1cdTAwMDJcdTAwMTHAmErN5DbfKst86f6jg717+2pe3N9Z9Fx1MDAxZkw3k0JTS1x1MDAxYU20XHUwMDEyXHUwMDE0/aSMJ9tnXHUwMDEye7XhOnNcdTAwMDeZXHUwMDFj6HUuUWiCXHUwMDEw0om6RDyhXGaDpDwzhfDl939+8dXfTp7/4/hcdTAwMGY/XHUwMDFkPf/veGFcdTAwMWNpPFMoiVx1MDAxZVx1MDAwNSW6XHUwMDEwXHUwMDBlSpBcdTAwMTiQVzH5UXe9vr/+oNHBO8xvf+DUtyuHe1POpCFcdTAwMTbnTCtcZr4uXHUwMDA1rZxqXHUwMDBi11x1MDAwMJ1cdTAwMTbLXHUwMDBlR5WKRikkY5KwiXrEicD47Y9cdTAwMTPBMGl2Qlx1MDAwMGLMpFx1MDAxNUhB4yV7XHUwMDE1gbmlPF1ZX/qIbje3+FaVLs/nmtPuXHUwMDE1QVvoXHUwMDE5KSdcXFOCXHUwMDBlcIhBXGZklTKUgcCIVWXpXHUwMDE405FIXHQ1ilx0rWL3/Zag+PL500mgOGA2W1x1MDAxNEeWcKhcdTAwMTCYwlx1MDAwMFx1MDAxM+mdoThY39u5W4WS21xcsXNcdTAwMWRnrt1e6E05ilx1MDAxMixhOFx1MDAxMPyg6PlcdTAwMDdcdTAwMDNUQaRFlMRsXHUwMDEyXHUwMDE0z9YnUpZcdTAwMGVF/Fx1MDAxN2WW/K1cdTAwMGJRX3z6p6NnX1x1MDAxZT37/csvvp5cdTAwMDSTV9vPXHUwMDEyTsNHsqk0cE5uXHUwMDEyqHZ856B4r1sud7g9t7y0vLG68WFzytlUYEkuQVx1MDAwMmZkzKg4l+6zKWSUPEptaJRYZolmuuyRXHUwMDExg0emjLl4S8A8ef6vo8//PrHc8ZLx20Cy6Vx1MDAxNMNTUV7BZVwiXGZcdTAwMWHiklx1MDAxMco5V4anXHUwMDBmX2u1h9WFwiN7QVx1MDAxZoS7XHUwMDFi5YerxYJXmHIuubS4Jlx1MDAxMvXGubxcdTAwMTS+MnSaXGbjV6V1VIbNsqyjXHUwMDE0XHUwMDFlXHUwMDEwXGZwxSm67sROx5hcdTAwMWFuaaRcdTAwMDPk0Fx1MDAxOXHmTjHfXHUwMDEwilx1MDAxYlx1MDAxZM/wtak9XHUwMDE3USwjftby5PVgjoJcdTAwMTKRlPUrYH59RSdcdTAwMDObS2EgXHUwMDA3XFwjXFy81JLuQq77+F6TdHaX6/mguJLna4u16Za0opiR4brz4TDvVNDKMkQqYjBjXHUwMDAzXHUwMDE0PGSnaFBcdTAwMTYhTCqO2VYkWH5jSVx1MDAwM1x1MDAxNZG75Lfgh25b0ZIhb+S2XHUwMDE0PSpsXHUwMDFhXXNXSlxizGNvIGWvXHUwMDA3q3xV5dbqW3uduUP7frm2xKdcXMqCoTzOXHUwMDFmglxyn81cdTAwMThSgVAq47JCymRcdTAwMDZAa6Inm8tIwoi4ySn7ZiHTyb+/ffGX705+/unk2dOjL59cdTAwMWV/82y8UdN19rPMZfBkXHUwMDFkRaXAVIZcdTAwMTmm0z+c3t3Yme8+yuflYVvn8ltcdTAwMGal7NpT/q6IYtrSylxiTVx1MDAxOEXZXHI9nOaUW0ZcdFx1MDAwMlx1MDAwNCjGVYlM5/ZDJrAwZsOAh+CS41x0XHUwMDExS/+6UrySREtqJpnbSIbR0PhAXbc7rVNMXnz2XHUwMDFmTPmP//mbsVx1MDAxN1x1MDAxZV41hiyB5Wxk9UFqpVx1MDAxNFEk/ZPr9S394aq075aq5bn9hdzdnFx1MDAxNy7fn3JghUEkMVwipFpcdTAwMTJcdTAwMDFcdTAwMTCvRlx1MDAxZlipLUJcdTAwMDE1SZUxjGZcdTAwMDesXHUwMDAxyyCvavAxwXVcdTAwMTVCzVxyaK7UJJ+bSUG4UEmhZlxu6127XHUwMDEwNI++/uPx775cdTAwMWYvoVdcdTAwMWHOXHUwMDE0S1x1MDAxOJmpMcBIRiqT/p3LTqH1uKrWWrBcdTAwMWLM2d3uocip/WDKsZTEwpBcdTAwMTF5XHUwMDEwXHUwMDAyuYNBPypcYrVcdTAwMDRT0YunXFxm60fTlus1xtmE3UZ94fVhlETxm6Rdb1x1MDAwNuPRXz95+dlcdTAwMGb/+/m3R5/8cvzDd0e/jNlrXmc/89oghdFFeypccqeE8/SAXHUwMDE2cnq+vrCGXHUwMDE3kNbaY9+IpfWD/elcdTAwMDZcdTAwMTQoXHUwMDA2mEZIw85cblx1MDAxNFx1MDAwM4AyXHUwMDAyXHUwMDE2YcZcdTAwMTDNmMq2aP/mlVx1MDAxNCo5x/OG38Zj71svpUgtXHUwMDEyz4cyKqVIMkrMwKmSuMXpY8DGXn6ls1bczC9rr7ZfJYu7XHUwMDFlnfJCN0Z9XHUwMDE2XHUwMDE4XHUwMDE5ZT7RXHUwMDBiw8Ov90sremdXRVx1MDAxMjEkSy1LYYE2XHUwMDA2s8YzLadxPYDpJFx1MDAwN2Um6nlwtGp8nqdVtVx1MDAxYmN+nXjIZOb+hfGRL2xwrVhcdTAwMTT6p3/2tNrpdcRBLXD9nf3Q61x1MDAxNv1cdTAwMDft0tJ0I0lcdNVcdTAwMTZcdTAwMTDBXHUwMDE5ZTBI3bl/XHUwMDExhFx1MDAxOI2RMJiBOstcdTAwMTQ6XHUwMDE4bbiQOln5mlx1MDAxZf+iOWM6qess/ItcdTAwMTj99lx1MDAxMVx1MDAxMCZcdTAwMTgxJr2aRaOyuLKeI0ZcdTAwMWSWTc+piK1yrTjtalx1MDAwNrAozlx1MDAxMiRcdTAwMWaSyKmLMahmYVx1MDAxNDCV9X8hk1x1MDAxNlBjXHUwMDE0lUL31ZrGxWBcdTAwMDCgNFA60fo9XHUwMDBl4EZCfTNcdTAwMTezXFyqjNnDXGZavJGDwc/+ys3ajcZmiOt2cVDgRrmls8nH1mdcdTAwMGZcXKezcL1y7pxRXHUwMDFl8eT0T54nd578XHUwMDFmRUUmhyJ9 Color Texture 颜色直方图 颜色矩 颜色集 颜色聚合向量 颜色相关图 统计纹理分析 Laws纹理能量测量 Gabor变换 局部二值模式 shape Edge
Color
颜色直方图
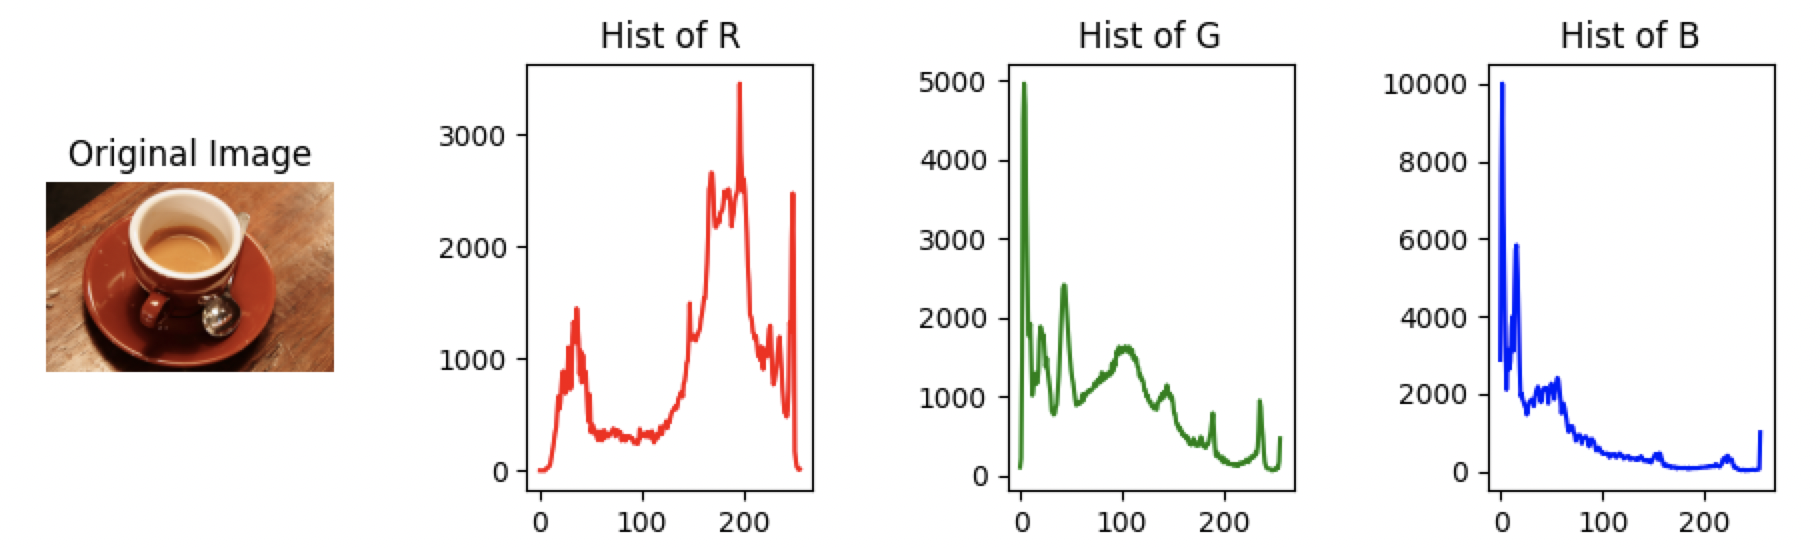
一般颜色直方图:某个色彩通道的直方图。
Code
from skimage import exposure,data
from matplotlib import pyplot as plt

image =data.coffee()

hist_r=exposure.histogram(image[:,:,0],nbins=256)
hist_g=exposure.histogram(image[:,:,1],nbins=256)
hist_b=exposure.histogram(image[:,:,2],nbins=256)

plt.subplot(1, 4, 1)
plt.imshow(image, cmap='gray')
plt.title('Original Image')
plt.axis('off')

plt.subplot(1, 4, 2)
plt.plot(hist_r[1], hist_r[0], color='red')
plt.title('Hist of R')

plt.subplot(1, 4, 3)
plt.plot(hist_g[1], hist_g[0], color='green')
plt.title('Hist of G')

plt.subplot(1, 4, 4)
plt.plot(hist_b[1], hist_b[0], color='blue')
plt.title('Hist of B')

plt.tight_layout()
plt.show()
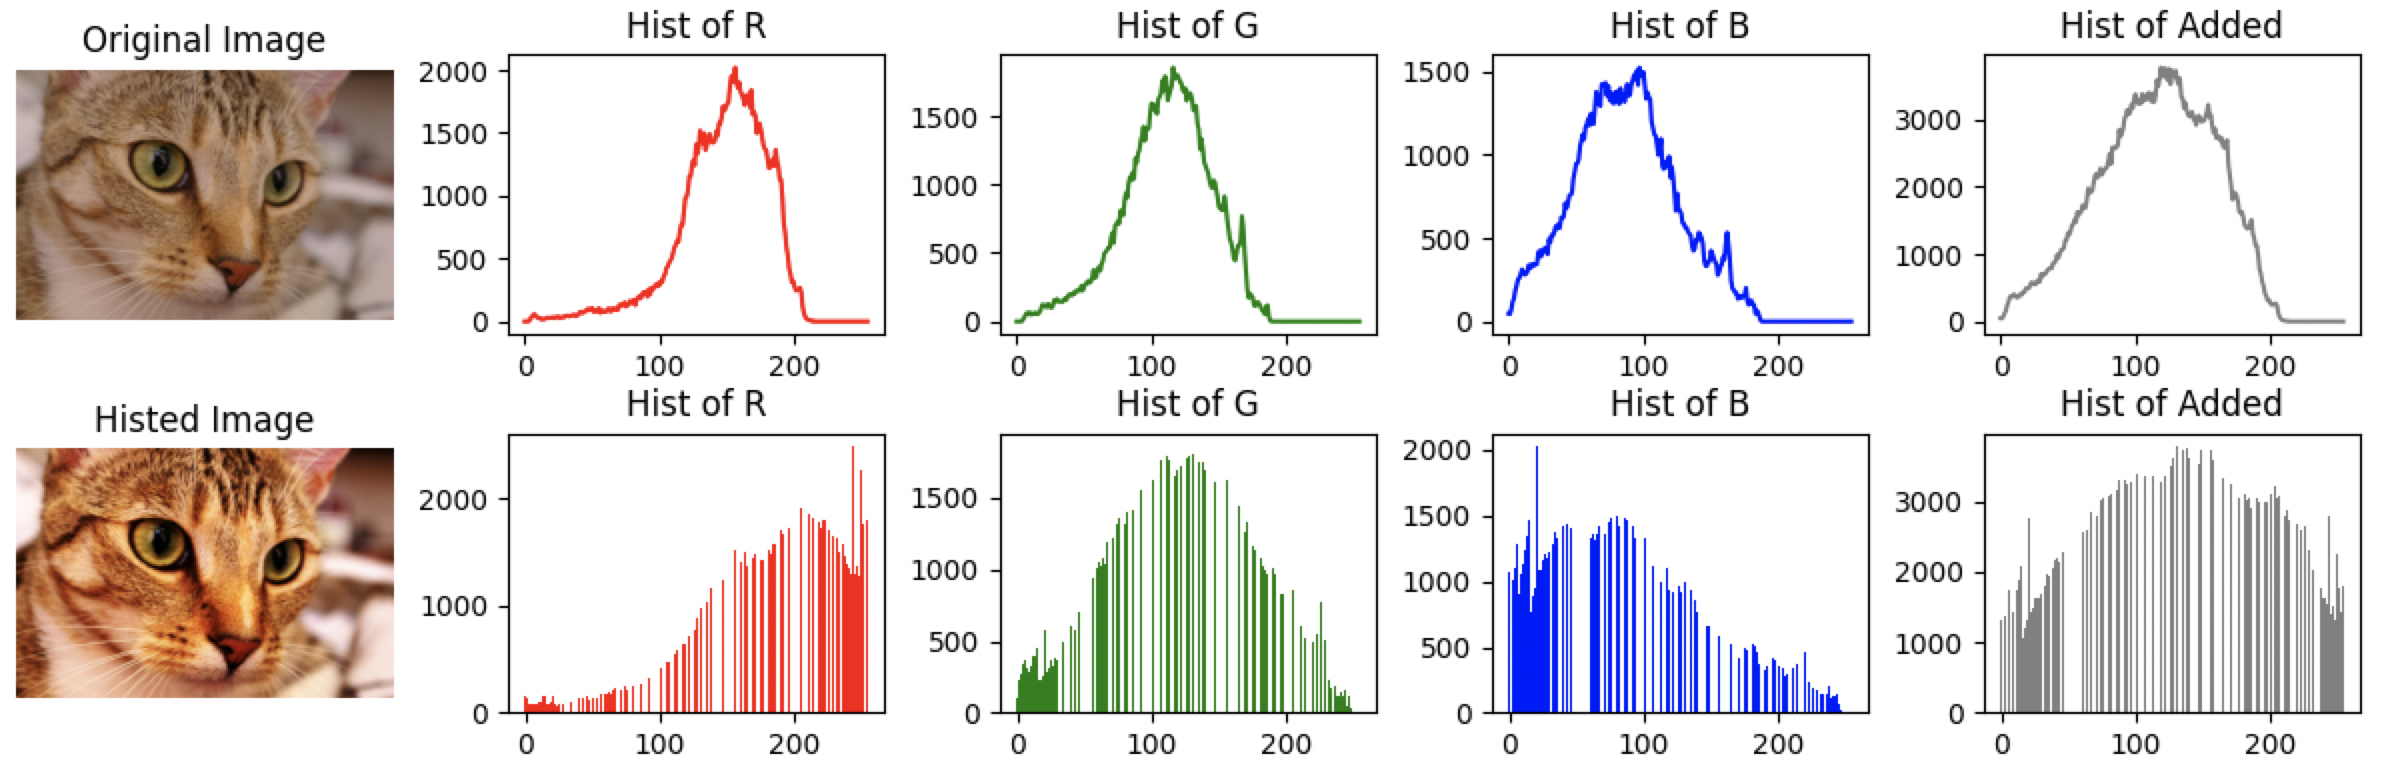
全局累加直方图:当图像中的特征并不能取遍所有可取值时,统计直方图中会出现一些零值 。这些零值的出现会对相似性度量的计算带来影响,从而使得相似性度量并不能正确反映图像之间的颜色差别。
Code
from skimage import data, exposure
from matplotlib import pyplot as plt
import numpy as np

# image = exposure.equalize_hist(data.chelsea())
image = data.cat()

bins = np.arange(256)
hist_r,bins=np.histogram(image[:,:,0], bins=bins, density=False)
hist_g,_=np.histogram(image[:,:,1], bins=bins, density=False)
hist_b,_=np.histogram(image[:,:,2], bins=bins, density=False)
hist_add=(hist_r+hist_g+hist_b)

plt.subplot(2, 5, 1)
plt.imshow(image, cmap='gray')
plt.title('Original Image')
plt.axis('off')

plt.subplot(2, 5, 2)
plt.plot(bins[:-1], hist_r, color='red')
plt.title('Hist of R')

plt.subplot(2, 5, 3)
plt.plot(bins[:-1], hist_g, color='green')
plt.title('Hist of G')

plt.subplot(2, 5, 4)
plt.plot(bins[:-1], hist_b, color='blue')
plt.title('Hist of B')

plt.subplot(2, 5, 5)
plt.plot(bins[:-1], hist_add, color='gray')
plt.title('Hist of Added')

image = exposure.equalize_hist(image)
image = (255.0*np.array(image)).astype(np.uint8)

bins = np.arange(256)
hist_r,bins=np.histogram(image[:,:,0], bins=bins, density=False)
hist_g,_=np.histogram(image[:,:,1], bins=bins, density=False)
hist_b,_=np.histogram(image[:,:,2], bins=bins, density=False)
hist_add=(hist_r+hist_g+hist_b)

plt.subplot(2, 5, 6)
plt.imshow(image, cmap='gray')
plt.title('Histed Image')
plt.axis('off')

plt.subplot(2, 5, 7)
plt.bar(bins[:-1], hist_r, color='red')
plt.title('Hist of R')

plt.subplot(2, 5, 8)
plt.bar(bins[:-1], hist_g, color='green')
plt.title('Hist of G')

plt.subplot(2, 5, 9)
plt.bar(bins[:-1], hist_b, color='blue')
plt.title('Hist of B')

plt.subplot(2, 5, 10)
plt.bar(bins[:-1], hist_add, color='gray')
plt.title('Hist of Added')

plt.tight_layout()
plt.show()
主色调直方图
在一幅图像中,不同颜色值出现的概率不尽相同,且通常情况下少数几种颜色就能涵盖整幅图像的主色调。基于该思想,主色调直方图法会计算出图像中每种颜色出现的频率,选择出现频率最高的几种颜色并将其作为主色调。使用主色调直方图并不会降低颜色直方图匹配的效果,反而会抑制图像非主要成分的噪声,降低噪声对图像匹配的影响。
{% hint style="warning" %}
颜色矩
一阶矩可以表征该颜色通道的平均响应强度
μ i = 1 N ∑ j = 1 N P i j 二阶矩可以表示该颜色通道的响应方差
σ i = [ 1 N ∑ j = 1 N ( P i j − μ i ) 2 ] 1 2 三阶矩可以表征该颜色通道数据分布的偏移度
s i = [ 1 N ∑ j = 1 N ( P i j − μ i ) 3 ] 1 3
You can't use 'macro parameter character #' in math mode p_{ij}$$表示数字图像P的第i个图像通道的第j个像素的像素值,N表示图像中像素的个数 {% endhint %} <details> <summary>Code</summary> ```python from skimage import data import numpy as np from scipy import stats image=data.coffee() #求 RGB图像的颜色矩特征,共9 维特征 #定义3×3 数组,分别对RGB图像的3个通道求均值、方差、偏移量 features=np.zeros(shape=(3,3)) #遍历图像的3个通道 for k in range(image.shape[2]): #求均值 mu=np.mean(image[:,:,k]) #求方差 delta=np.std(image[:,:,k]) #求偏移量 skew=np.mean(stats.skew(image[:,:,k])) features[0,k]=mu features[1,k]=delta features[2,k]=skew print(features) # [[158.5690875 85.794025 51.48475 ] # [ 62.97286712 60.95810371 52.93569362] # [ -0.71812328 0.53207991 1.36080834]] ``` </details> <details> <summary>颜色矩有什么用(GPT)</summary> 颜色矩在图像处理领域中扮演着重要的角色,它们被用来描述和量化图像的颜色分布。以下是颜色矩的一些主要用途: 1. **颜色特征提取**:颜色矩可以作为图像的特征提取方法,用于描述图像颜色的空间分布和强度变化。通过计算图像中不同颜色通道(如红色、绿色、蓝色等)的均值、方差、熵等统计量,可以得到一组具有代表性的颜色特征向量。这些特征向量可以用来表示图像的颜色模式,从而进行图像分类、检索和分析。 2. **图像去噪**:在图像去噪过程中,颜色矩可以帮助区分噪声和有用信号。例如,高斯噪声通常会在整个图像上均匀分布,而真实图像中的颜色模式则往往呈现出特定的结构。因此,可以使用颜色矩来检测这种结构,并通过去除与结构无关的噪声成分来提高图像的质量。 3. **图像增强**:颜色矩也可以用于图像增强。通过调整图像中各颜色通道的亮度、对比度和饱和度,可以改善图像的可视性和可读性。例如,可以通过增加图像中某些颜色通道的权重来强调其重要性,从而使图像中的特定区域或特征更加突出。 4. **图像压缩**:在图像压缩过程中,颜色矩可以帮助减少数据的冗余度。通过编码图像中常见的颜色模式,可以将图像转换为一种更紧凑的形式。这样,即使在压缩后,仍然能够恢复出高质量的图像。 5. **图像风格迁移**:在图像风格迁移任务中,颜色矩可以作为目标风格的描述符。通过比较源图像和目标图像的颜色矩,可以指导风格转换过程,使得生成的图像更接近目标风格。 6. **图像识别与理解**:在图像识别和理解任务中,颜色矩可以作为机器学习模型的输入特征。例如,在物体识别任务中,颜色矩可以用来描述物体的颜色特征,从而帮助模型更好地识别和分类物体。 7. **艺术创作**:艺术家和设计师也可以利用颜色矩来进行艺术创作。通过分析和理解图像中的颜色模式,可以创造出更具视觉吸引力和情感表达力的作品。 总之,颜色矩是一种强大的图像处理工具,它可以在多种不同的应用场景中发挥作用,从图像去噪、增强到风格迁移和艺术创作,展示了其在图像处理领域的广泛适用性。 </details> ### 颜色集 颜色集又可以称为颜色索引集,其是对图像颜色直方图的一种近似。 方案一:通过颜色直方图 {% hint style="info" %} 其实我看就是对颜色直方图进行一遍筛选。 {% endhint %} 1. 将图像从RGB颜色空间转换到HSV颜色空间等视觉均衡的颜色空间,并将颜色空间量化为若干个边长均等的小立方体; 2. 使用基于色彩的自动分割技术将图像划分为若干个子区域; 3. 使用颜色量化空间中的某个颜色分类索引每个子区域,以将图像表示为一个二进制的颜色索引集。 最简单的颜色集可以通过在颜色直方图的基础上设置阈值形成。如给定某一颜色值m,给定其阈值τm,由颜色直方图生成颜色集c可表示为: p_{ij}$$表示数字图像P的第i个图像通道的第j个像素的像素值,N表示图像中像素的个数 {% endhint %} <details> <summary>Code</summary> ```python from skimage import data import numpy as np from scipy import stats image=data.coffee() #求 RGB图像的颜色矩特征,共9 维特征 #定义3×3 数组,分别对RGB图像的3个通道求均值、方差、偏移量 features=np.zeros(shape=(3,3)) #遍历图像的3个通道 for k in range(image.shape[2]): #求均值 mu=np.mean(image[:,:,k]) #求方差 delta=np.std(image[:,:,k]) #求偏移量 skew=np.mean(stats.skew(image[:,:,k])) features[0,k]=mu features[1,k]=delta features[2,k]=skew print(features) # [[158.5690875 85.794025 51.48475 ] # [ 62.97286712 60.95810371 52.93569362] # [ -0.71812328 0.53207991 1.36080834]] ``` </details> <details> <summary>颜色矩有什么用(GPT)</summary> 颜色矩在图像处理领域中扮演着重要的角色,它们被用来描述和量化图像的颜色分布。以下是颜色矩的一些主要用途: 1. **颜色特征提取**:颜色矩可以作为图像的特征提取方法,用于描述图像颜色的空间分布和强度变化。通过计算图像中不同颜色通道(如红色、绿色、蓝色等)的均值、方差、熵等统计量,可以得到一组具有代表性的颜色特征向量。这些特征向量可以用来表示图像的颜色模式,从而进行图像分类、检索和分析。 2. **图像去噪**:在图像去噪过程中,颜色矩可以帮助区分噪声和有用信号。例如,高斯噪声通常会在整个图像上均匀分布,而真实图像中的颜色模式则往往呈现出特定的结构。因此,可以使用颜色矩来检测这种结构,并通过去除与结构无关的噪声成分来提高图像的质量。 3. **图像增强**:颜色矩也可以用于图像增强。通过调整图像中各颜色通道的亮度、对比度和饱和度,可以改善图像的可视性和可读性。例如,可以通过增加图像中某些颜色通道的权重来强调其重要性,从而使图像中的特定区域或特征更加突出。 4. **图像压缩**:在图像压缩过程中,颜色矩可以帮助减少数据的冗余度。通过编码图像中常见的颜色模式,可以将图像转换为一种更紧凑的形式。这样,即使在压缩后,仍然能够恢复出高质量的图像。 5. **图像风格迁移**:在图像风格迁移任务中,颜色矩可以作为目标风格的描述符。通过比较源图像和目标图像的颜色矩,可以指导风格转换过程,使得生成的图像更接近目标风格。 6. **图像识别与理解**:在图像识别和理解任务中,颜色矩可以作为机器学习模型的输入特征。例如,在物体识别任务中,颜色矩可以用来描述物体的颜色特征,从而帮助模型更好地识别和分类物体。 7. **艺术创作**:艺术家和设计师也可以利用颜色矩来进行艺术创作。通过分析和理解图像中的颜色模式,可以创造出更具视觉吸引力和情感表达力的作品。 总之,颜色矩是一种强大的图像处理工具,它可以在多种不同的应用场景中发挥作用,从图像去噪、增强到风格迁移和艺术创作,展示了其在图像处理领域的广泛适用性。 </details> ### 颜色集 颜色集又可以称为颜色索引集,其是对图像颜色直方图的一种近似。 方案一:通过颜色直方图 {% hint style="info" %} 其实我看就是对颜色直方图进行一遍筛选。 {% endhint %} 1. 将图像从RGB颜色空间转换到HSV颜色空间等视觉均衡的颜色空间,并将颜色空间量化为若干个边长均等的小立方体; 2. 使用基于色彩的自动分割技术将图像划分为若干个子区域; 3. 使用颜色量化空间中的某个颜色分类索引每个子区域,以将图像表示为一个二进制的颜色索引集。 最简单的颜色集可以通过在颜色直方图的基础上设置阈值形成。如给定某一颜色值m,给定其阈值τm,由颜色直方图生成颜色集c可表示为: c[m]=\begin{cases}1&h[m]≥\tau_m\0&others\end
You can't use 'macro parameter character #' in math mode 方案二:通过色彩空间变换再量化来减少颜色 1. 像素矢量表示对于RGB空间中的任意图像,它的每个像素均可表示为一个矢量\[插图]=(r,g,b),其中r、g、b分别代表红、绿、蓝颜色分量。 2. 颜色空间转换通过变换运算T将图像变换到一个与人视觉一致的颜色空间\[插图],即\[插图]。 3. 颜色集索引采用量化器(QM)对\[插图]重新量化,使得视觉上明显不同的颜色对应不同的颜色集,并将颜色集映射成索引m。 4. 颜色集表示设BM是M维的二值空间,在该空间中每个轴对应唯一的索引m。一个颜色集就是BM二值空间中的一个二维矢量,它表示对颜色{m}的选择,即颜色m出现时,c\[m]=1,否则c\[m]=0。 ### 颜色聚合向量 {% hint style="info" %} 颜色集,是对颜色直方图的筛选。颜色聚合向量,是表示颜色间的关系,代表颜色的变化。 {% endhint %} 颜色聚合向量是在颜色直方图的基础之上做的进一步运算。**其核心思想是将属于颜色直方图的每个颜色量化区间的像素分为两部分,如果该颜色量化区间中的某些像素占据的连续区域的面积大于指定阈值,则将该区域内的像素作为聚合像素,否则作为非聚合像素**。 颜色聚合向量可表示为<(α1,β1),,(αn,βn)>,其中αi与βi分别代表颜色直方图的第i个颜色量化区间中的聚合像素和非聚合像素的数量。颜色聚合向量除了包含颜色频率信息外,也包含颜色的部分空间分布信息,因此其可以获得比颜色直方图更好的表示效果。颜色聚合向量算法的步骤如下。 1\. 量化:颜色聚合向量算法的第一步与求普通的颜色直方图类似,即对图像进行量化处理。一般采用均匀量化处理方法,量化的目标是使图像中只保留有限个颜色区间。 2\. 连通区域划分针对重新量化后的像素值矩阵,根据像素间的连通性把图像划分成若干个连通区域。 3\. 判断聚合性统计每个连通区域中的像素数目,根据设定的阈值判断该区域中的像素是聚合的,还是非聚合,得出每个颜色区间中聚合像素和非聚合像素的数量αi和βi。 4\. 聚合向量形成图像的聚合向量可以表示为〈(α1,β1),,(αn,βn)〉。 ### 颜色相关图 {% hint style="info" %} 颜色相关图 = 颜色聚合向量 + 位置信息 {% endhint %} 颜色相关图是图像颜色分布的另外一种表达方式。颜色相关图不仅可以显示像素在图像中的占比,也可以反映不同颜色对间的空间位置的相关性。颜色相关图利用颜色对间的相对距离分布来描述空间位置信息。 方案二:通过色彩空间变换再量化来减少颜色 1. 像素矢量表示对于RGB空间中的任意图像,它的每个像素均可表示为一个矢量\[插图]=(r,g,b),其中r、g、b分别代表红、绿、蓝颜色分量。 2. 颜色空间转换通过变换运算T将图像变换到一个与人视觉一致的颜色空间\[插图],即\[插图]。 3. 颜色集索引采用量化器(QM)对\[插图]重新量化,使得视觉上明显不同的颜色对应不同的颜色集,并将颜色集映射成索引m。 4. 颜色集表示设BM是M维的二值空间,在该空间中每个轴对应唯一的索引m。一个颜色集就是BM二值空间中的一个二维矢量,它表示对颜色{m}的选择,即颜色m出现时,c\[m]=1,否则c\[m]=0。 ### 颜色聚合向量 {% hint style="info" %} 颜色集,是对颜色直方图的筛选。颜色聚合向量,是表示颜色间的关系,代表颜色的变化。 {% endhint %} 颜色聚合向量是在颜色直方图的基础之上做的进一步运算。**其核心思想是将属于颜色直方图的每个颜色量化区间的像素分为两部分,如果该颜色量化区间中的某些像素占据的连续区域的面积大于指定阈值,则将该区域内的像素作为聚合像素,否则作为非聚合像素**。 颜色聚合向量可表示为<(α1,β1),,(αn,βn)>,其中αi与βi分别代表颜色直方图的第i个颜色量化区间中的聚合像素和非聚合像素的数量。颜色聚合向量除了包含颜色频率信息外,也包含颜色的部分空间分布信息,因此其可以获得比颜色直方图更好的表示效果。颜色聚合向量算法的步骤如下。 1\. 量化:颜色聚合向量算法的第一步与求普通的颜色直方图类似,即对图像进行量化处理。一般采用均匀量化处理方法,量化的目标是使图像中只保留有限个颜色区间。 2\. 连通区域划分针对重新量化后的像素值矩阵,根据像素间的连通性把图像划分成若干个连通区域。 3\. 判断聚合性统计每个连通区域中的像素数目,根据设定的阈值判断该区域中的像素是聚合的,还是非聚合,得出每个颜色区间中聚合像素和非聚合像素的数量αi和βi。 4\. 聚合向量形成图像的聚合向量可以表示为〈(α1,β1),,(αn,βn)〉。 ### 颜色相关图 {% hint style="info" %} 颜色相关图 = 颜色聚合向量 + 位置信息 {% endhint %} 颜色相关图是图像颜色分布的另外一种表达方式。颜色相关图不仅可以显示像素在图像中的占比,也可以反映不同颜色对间的空间位置的相关性。颜色相关图利用颜色对间的相对距离分布来描述空间位置信息。 \gamma_{i,j}^{(k)}=\underset{p_1\in I_{(i)}, p_2\in I}{\operatorname{P}}[p_2\in I_{(j)}\mid |p_1-p_2|=k]
You can't use 'macro parameter character #' in math mode  <details> <summary>Code</summary> ```python import numpy as np from skimage.data import coffee from matplotlib import pyplot as plt def isValid(X, Y, point): """ 判断某个像素是否超出图像空间范围 """ if point[0] < 0 or point[0] >= X: return False if point[1] < 0 or point[1] >= Y: return False return True def getNeighbors(X, Y, x, y, dist): """ Find pixel neighbors according to various distances """ cn1 = (x + dist, y + dist) cn2 = (x + dist, y) cn3 = (x + dist, y - dist) cn4 = (x, y - dist) cn5 = (x - dist, y - dist) cn6 = (x - dist, y) cn7 = (x - dist, y + dist) cn8 = (x, y + dist) points = (cn1, cn2, cn3, cn4, cn5, cn6, cn7, cn8) Cn = [] for i in points: if isValid(X, Y, i): Cn.append(i) return Cn def corrlogram(image,dist): XX,YY,tt=image.shape cgram=np.zeros((256,256),dtype=np.uint32) for x in range(XX): for y in range(YY): for t in range(tt): color_i=image[x,y,t] neighbors_i=getNeighbors(XX,YY,x,y,dist) for j in neighbors_i: j0=j[0] j1=j[1] color_j=image[j0,j1,t] cgram[color_i,color_j]=cgram[color_i,color_j]+1 return cgram image=coffee() dist=4 cgram=corrlogram(image,dist) plt.subplot(1,2,1) plt.imshow(cgram) plt.subplot(1,2,2) plt.imshow(np.log(cgram+1))# 看不清,所以用 log 减少一下像素亮度差异 plt.show() ``` </details> *** ## Texture <details> <summary>Overview</summary> 数字图像处理—图像纹理特征[1]播客中的图片\[1] 综述[2]综述总结\[2] [https://github.com/cgreen259/Texture-Toolbox](https://github.com/cgreen259/Texture-Toolbox) </details> ### 统计纹理分析方法 #### AutoCorrelation Function(自相关函数) 要理解 2D 的自相关函数还是先看看一维的自相关函数。自相关函数代表了一个信号移动一些距离,和自己是相像的程度! 参考了[5],但不一样 <details> <summary>Code</summary> ```python import statsmodels.api as sm import matplotlib.pyplot as plt import numpy as np # 定义正弦波函数 def sin_wave(t): return np.sin(2*np.pi*t) # 生成时间序列 t = np.arange(0, np.pi, 0.005) # 添加噪声 noise = np.random.normal(0, 0.2, len(t)) # 合并信号和噪声 signal = sin_wave(t) signal_with_noise = signal + noise # Calculate autocorrelations acf_res1 = sm.tsa.acf(signal,nlags=len(signal)) acf_res2 = sm.tsa.acf(signal_with_noise,nlags=len(signal)) # 绘制带有噪声的正弦波 plt.figure(figsize=(15, 4)) plt.subplot(1,4,1) plt.plot(t, signal, label='Signal') plt.title('Sinusoidal Signal sin(2πt)') plt.xlabel('Time') plt.ylabel('Amplitude') plt.grid(True) plt.subplot(1,4,2) plt.plot(t, acf_res1) plt.title('Autocorrelation Plot') plt.xlabel('Time') plt.ylabel('Autocorrelation') plt.grid(True) plt.subplot(1,4,3) plt.plot(t, signal_with_noise, label='Signal with Noise') plt.title('Sinusoidal Signal with Noise') plt.xlabel('Time') plt.ylabel('Amplitude') plt.grid(True) plt.subplot(1,4,4) plt.plot(t, acf_res2) plt.title('Autocorrelation Plot') plt.xlabel('Time') plt.ylabel('Autocorrelation') plt.grid(True) plt.show() ``` </details> 接下来就是图像的自相关函数: {% hint style="info" %} 注意下面的公式 range 是matlab 对图像的索引,所以从 1 开始,如果用 Python就要再减一 {% endhint %}  <details> <summary>Code</summary> ```python import numpy as np from skimage.data import coffee from matplotlib import pyplot as plt def isValid(X, Y, point): """ 判断某个像素是否超出图像空间范围 """ if point[0] < 0 or point[0] >= X: return False if point[1] < 0 or point[1] >= Y: return False return True def getNeighbors(X, Y, x, y, dist): """ Find pixel neighbors according to various distances """ cn1 = (x + dist, y + dist) cn2 = (x + dist, y) cn3 = (x + dist, y - dist) cn4 = (x, y - dist) cn5 = (x - dist, y - dist) cn6 = (x - dist, y) cn7 = (x - dist, y + dist) cn8 = (x, y + dist) points = (cn1, cn2, cn3, cn4, cn5, cn6, cn7, cn8) Cn = [] for i in points: if isValid(X, Y, i): Cn.append(i) return Cn def corrlogram(image,dist): XX,YY,tt=image.shape cgram=np.zeros((256,256),dtype=np.uint32) for x in range(XX): for y in range(YY): for t in range(tt): color_i=image[x,y,t] neighbors_i=getNeighbors(XX,YY,x,y,dist) for j in neighbors_i: j0=j[0] j1=j[1] color_j=image[j0,j1,t] cgram[color_i,color_j]=cgram[color_i,color_j]+1 return cgram image=coffee() dist=4 cgram=corrlogram(image,dist) plt.subplot(1,2,1) plt.imshow(cgram) plt.subplot(1,2,2) plt.imshow(np.log(cgram+1))# 看不清,所以用 log 减少一下像素亮度差异 plt.show() ``` </details> *** ## Texture <details> <summary>Overview</summary> 数字图像处理—图像纹理特征[1]播客中的图片\[1] 综述[2]综述总结\[2] [https://github.com/cgreen259/Texture-Toolbox](https://github.com/cgreen259/Texture-Toolbox) </details> ### 统计纹理分析方法 #### AutoCorrelation Function(自相关函数) 要理解 2D 的自相关函数还是先看看一维的自相关函数。自相关函数代表了一个信号移动一些距离,和自己是相像的程度! 参考了[5],但不一样 <details> <summary>Code</summary> ```python import statsmodels.api as sm import matplotlib.pyplot as plt import numpy as np # 定义正弦波函数 def sin_wave(t): return np.sin(2*np.pi*t) # 生成时间序列 t = np.arange(0, np.pi, 0.005) # 添加噪声 noise = np.random.normal(0, 0.2, len(t)) # 合并信号和噪声 signal = sin_wave(t) signal_with_noise = signal + noise # Calculate autocorrelations acf_res1 = sm.tsa.acf(signal,nlags=len(signal)) acf_res2 = sm.tsa.acf(signal_with_noise,nlags=len(signal)) # 绘制带有噪声的正弦波 plt.figure(figsize=(15, 4)) plt.subplot(1,4,1) plt.plot(t, signal, label='Signal') plt.title('Sinusoidal Signal sin(2πt)') plt.xlabel('Time') plt.ylabel('Amplitude') plt.grid(True) plt.subplot(1,4,2) plt.plot(t, acf_res1) plt.title('Autocorrelation Plot') plt.xlabel('Time') plt.ylabel('Autocorrelation') plt.grid(True) plt.subplot(1,4,3) plt.plot(t, signal_with_noise, label='Signal with Noise') plt.title('Sinusoidal Signal with Noise') plt.xlabel('Time') plt.ylabel('Amplitude') plt.grid(True) plt.subplot(1,4,4) plt.plot(t, acf_res2) plt.title('Autocorrelation Plot') plt.xlabel('Time') plt.ylabel('Autocorrelation') plt.grid(True) plt.show() ``` </details> 接下来就是图像的自相关函数: {% hint style="info" %} 注意下面的公式 range 是matlab 对图像的索引,所以从 1 开始,如果用 Python就要再减一 {% endhint %} ho(x,y)=\frac{\frac{1}{(N_i-\left|x\right|)(N_j-\left|y\right|)}\sum_{i}\sum_{j}I(i,j)I(i+x,j+y)}{\frac{1}{N_i N_j}\sum_{i=1}^{N_i}\sum_{j=1}^{N_j}I(i,j)^2}
You can't use 'macro parameter character #' in math mode condition ), # Gray Level 'E3': np.array([[ 1, 0, -1]]), # Edge 'S3': np.array([[ 1, 2, -1]]), # Spot(点) 'L5': np.array([[ 1, 4, 6, 4, 1]]), 'E5': np.array([[ -1, -2, 0, 2, 1]]), 'S5': np.array([[ -1, 0, 2, 0, -1]]), 'W5': np.array([[ -1, 2, 0, -2, 1]]), # Wave 'R5': np.array([[ 1, -4, 6, -4, 1]]), # 涟漪(Ripple) 'R5': np.array([[ 1, -4, 6, -4, 1]]), # 涟漪(Ripple) 'L7': np.array([[ 1, 6, 15, 20, 15, 6, 1]]), 'E7': np.array([[ -1, -4, -5, 0, 5, 4, 1]]), 'S7': np.array([[ -1, -2, 1, 4, 1, -2, -1]]), 'W7': np.array([[ -1, 0, 3, 0, -3, 0, 1]]), 'R7': np.array([[ 1, -2, -1, 4, -1, -2, 1]]), 'O7': np.array([[ -1, 6, -15, 20, -15, 6, -1]]), # 振荡(Oscillation) } # 创建更复杂的Laws滤波器 laws_filters = { 'E5L5': np.dot(basic_filters['E5'].T, basic_filters['L5']), 'R5R5': np.dot(basic_filters['R5'].T, basic_filters['R5']), 'E5S5': np.dot(basic_filters['E5'].T, basic_filters['S5']), 'L5S5': np.dot(basic_filters['L5'].T, basic_filters['S5']), } # ... 可以添加更多组合 # 读取图像 from skimage import data image = data.camera().astype(np.float32) # 初始化纹理能量字典 texture_energies = {} filtered_images = {} # 应用Laws滤波器并计算纹理能量 for filter_name, filter_kernel in laws_filters.items(): # 应用滤波器 filtered_images[filter_name] = cv2.filter2D(image, -1, filter_kernel) # 计算纹理能量 energy = np.sum(filtered_images[filter_name]**2) # type: ignore # 保存结果 texture_energies[filter_name] = energy # 打印纹理能量 for filter_name, energy in texture_energies.items(): print(f"Texture energy for {filter_name}: {energy}") # 可视化滤波后的图像(可选) def plot(n,index,image,name): plt.subplot(1,n,index) plt.imshow(image, cmap='gray') plt.title(name) plt.axis('off') plot(5,1,image,'Origin') for i, (name, image) in enumerate(zip(laws_filters.keys(), filtered_images.values())): plot(5,i+2,image,name) plt.tight_layout() plt.show() ``` </details> ### Gabor变换 Babor kernel 是高斯乘正弦波。 具体方案就是图像和Babor kernel分别变换到频率域,然后做乘法,再变回来。 G_{\sigma,f_0,\phi}(x,y)=\exp\left(-\frac{1}{2}\left[\frac{x'^2}{\sigma_x^2}+\frac{y'^2}{\sigma_y^2}\right]\right)\cos(2\pi f_0 x'+\phi)
\begin{aligned} &x'=x\cos(\theta)+y\sin(\theta),\ &y'=-x\sin(\theta)+y\cos(\theta). \end
You can't use 'macro parameter character #' in math mode  <details> <summary>Code</summary> ```python import matplotlib.pyplot as plt import numpy as np from scipy import ndimage as ndi from skimage import data from skimage.filters import gabor_kernel def compute_feats(image, kernels): feats = np.zeros((len(kernels), 2), dtype=np.double) for k, kernel in enumerate(kernels): filtered = ndi.convolve(image, kernel, mode='wrap') feats[k, 0] = filtered.mean() feats[k, 1] = filtered.var() return feats def match(feats, ref_feats): min_error = np.inf min_i = None for i in range(ref_feats.shape[0]): error = np.sum((feats - ref_feats[i, :])**2) if error < min_error: min_error = error min_i = i return min_i # 准备Gabor卷积核 kernels = [] for theta in range(4): theta = theta / 4. * np.pi for sigma in (1, 3): for frequency in (0.05, 0.25): kernel = np.real(gabor_kernel(frequency, theta=theta,sigma_x=sigma, sigma_y=sigma)) kernels.append(kernel) shrink = (slice(0, None, 3), slice(0, None, 3)) brick = data.brick().astype(np.float64) grass = data.grass().astype(np.float64) checkerboard = data.checkerboard().astype(np.float64) # brick = data.load('brick.png')[shrink] # grass = img_as_float(data.load('grass.png'))[shrink] # wall = img_as_float(data.load('rough-wall.png'))[shrink] # image_names = ('砖块', '草地', '墙壁') image_names = ('brick','grass','checkerboard') # images = (brick, grass, wall) images = [brick, grass, checkerboard] # 准备参考特征 ref_feats = np.zeros((3, len(kernels), 2), dtype=np.double) ref_feats[0, :, :] = compute_feats(brick, kernels) ref_feats[1, :, :] = compute_feats(grass, kernels) ref_feats[2, :, :] = compute_feats(checkerboard, kernels) def power(image, kernel): # Normalize images for better comparison. 05 image = (image - image.mean()) / image.std() return np.sqrt(ndi.convolve(image, np.real(kernel), mode='wrap')**2 +ndi.convolve(image, np.imag(kernel), mode='wrap')**2) # Plot a selection of the filter bank kernels and their responses. results = [] kernel_params = [] for theta in (0, 1): theta = theta / 4. * np.pi for frequency in (0.1, 0.4): kernel = gabor_kernel(frequency, theta=theta) params = 'theta=%d,\nfrequency=%.2f' % (theta * 180 / np.pi, frequency) kernel_params.append(params) # Save kernel and the power image for each image results.append((kernel, [power(img, kernel) for img in images])) fig, axes = plt.subplots(nrows=5, ncols=4, figsize=(5, 6)) plt.gray() fig.suptitle('Image responses for Gabor filter kernels', fontsize=12) axes[0][0].axis('off') # Plot original images for label, img, ax in zip(image_names, images, axes[0][1:]): ax.imshow(img) ax.set_title(label, fontsize=9) ax.axis('off') for label, (kernel, powers), ax_row in zip(kernel_params, results, axes[1:]): # Plot Gabor kernel ax = ax_row[0] ax.imshow(np.real(kernel), interpolation='nearest') ax.set_xlabel(label, fontsize=7) ax.set_xticks([]) ax.set_yticks([]) # Plot Gabor responses with the contrast normalized for each filter vmin = min([np.min(item) for item in powers]) vmax = max([np.max(item) for item in powers]) for patch, ax in zip(powers, ax_row[1:]): ax.imshow(patch, vmin=vmin, vmax=vmax) ax.axis('off') plt.show() ``` </details> ### 局部二值模式 (Local Binary Pattern, BLP) {% hint style="info" %} 通过中心像素与相邻像素的亮度区别,体现出了亮度变换,也就是梯度。 {% endhint %} 基本的LBP算子:3×3的矩形块,有1个中心像素和8个邻域像素分别对应9个灰度值。以中心像素的灰度值为阈值,将其邻域的8个灰度值与阈值比较,大于中心灰度值的像素用1表示,反之用0表示。 根据顺时针方向读出8个二进制值。每个位置有自己的权重。求出这个 3 x 3 的块的值。(下图 为 25) [10] 因为人类视觉系统对纹理的感知与平均灰度(亮度)无关,而局部二值模式方法注重像素灰度的变化,所以它符合人类视觉对图像纹理的感知特点。LBP计算过程如图5-6所示。    <details> <summary>Code</summary> ```python """ 基于二值模式的图像纹理分类 """ import numpy as np import matplotlib.pyplot as plt METHOD = 'uniform' # plt.rcParams['font.size'] = 9 def plot_circle(ax, center, radius, color): circle = plt.Circle(center, radius, facecolor=color,edgecolor='0.5') ax.add_patch(circle) def plot_lbp_model(ax, binary_values): """LBP 方法模型绘制.""" # Geometry spec theta = np.deg2rad(45) R = 1 r = 0.15 w = 1.5 gray = '0.5' # Draw the central pixel. plot_circle(ax, (0, 0), radius=r, color=gray) # Draw the surrounding pixels. for i, facecolor in enumerate(binary_values): x = R * np.cos(i * theta) y = R * np.sin(i * theta) plot_circle(ax, (x, y), radius=r, color=str(facecolor)) # Draw the pixel grid. for x in np.linspace(-w, w, 4): ax.axvline(x, color=gray) ax.axhline(x, color=gray) # Tweak the layout. ax.axis('image') ax.axis('off') size = w + 0.2 ax.set_xlim(-size, size) ax.set_ylim(-size, size) fig, axes = plt.subplots(ncols=5, figsize=(7, 2)) titles = ['flat', 'flat', 'edge', 'corner', 'non-uniform'] binary_patterns = [np.zeros(8), np.ones(8), np.hstack([np.ones(4), np.zeros(4)]), np.hstack([np.zeros(3), np.ones(5)]), [1, 0, 0, 1, 1, 1, 0, 0]] for ax, values, name in zip(axes, binary_patterns, titles): plot_lbp_model(ax, values) ax.set_title(name) #二值模式特征提取部分 from skimage.transform import rotate from skimage.feature import local_binary_pattern from skimage import data from skimage.color import label2rgb # settings for LBP radius = 3 n_points = 8 * radius def overlay_labels(image, lbp, labels): mask = np.logical_or.reduce([lbp == each for each in labels]) return label2rgb(mask, image=image, bg_label=0, alpha=0.5) def highlight_bars(bars, indexes): for i in indexes: bars[i].set_facecolor('r') image = data.brick() lbp = local_binary_pattern(image, n_points, radius, METHOD) def hist(ax, lbp): n_bins = int(lbp.max() + 1) return ax.hist(lbp.ravel(), bins=n_bins, range= (0, n_bins), facecolor='0.5')# normed=True, # 绘制LBP直方图 fig, (ax_img, ax_hist) = plt.subplots(nrows=2, ncols=3, figsize=(9, 6)) plt.gray() titles = ('edge', 'flat', 'corner') w = width = radius - 1 edge_labels = range(n_points // 2 - w, n_points // 2 + w + 1) flat_labels = list(range(0, w + 1)) + list(range(n_points - w, n_points + 2)) i_14 = n_points // 4 # 1/4th of the histogram i_34 = 3 * (n_points // 4) # 3/4th of the histogram corner_labels = (list(range(i_14 - w, i_14 + w + 1)) + list(range(i_34 - w, i_34 + w + 1))) label_sets = (edge_labels, flat_labels, corner_labels) for ax, labels in zip(ax_img, label_sets): ax.imshow(overlay_labels(image, lbp, labels)) for ax, labels, name in zip(ax_hist, label_sets, titles): counts, _, bars = hist(ax, lbp) highlight_bars(bars, labels) ax.set_ylim(top=np.max(counts[:-1])) ax.set_xlim(right=n_points + 2) ax.set_title(name) ax_hist[0].set_ylabel('Percentage') for ax in ax_img: ax.axis('off') #使用LBP对图像纹理进行分类 radius = 2 n_points = 8 * radius def kullback_leibler_divergence(p, q): p = np.asarray(p) q = np.asarray(q) filt = np.logical_and(p != 0, q != 0) return np.sum(p[filt] * np.log2(p[filt] / q[filt])) def match(refs, img): best_score = 10 best_name = None lbp = local_binary_pattern(img, n_points, radius, METHOD) n_bins = int(lbp.max() + 1) hist, _ = np.histogram(lbp, density=True, bins=n_bins, range= (0, n_bins)) for name, ref in refs.items(): ref_hist, _ = np.histogram(ref, density=True, bins=n_bins, range=(0, n_bins)) score = kullback_leibler_divergence(hist, ref_hist) if score < best_score: best_score = score best_name = name return best_name brick = data.brick() grass = data.grass() wall = data.gravel() refs = { 'brick': local_binary_pattern(brick, n_points, radius, METHOD), 'grass': local_binary_pattern(grass, n_points, radius, METHOD), 'wall': local_binary_pattern(wall, n_points, radius, METHOD) } # 对特征进行分类 print('Rotated images matched against references using LBP:') print('original: brick, rotated: 30deg, match result: ', match(refs, rotate(brick, angle=30, resize=False))) print('original: brick, rotated: 70deg, match result: ', match(refs, rotate(brick, angle=70, resize=False))) print('original: grass, rotated: 145deg, match result: ', match(refs, rotate(grass, angle=145, resize=False))) # 绘制LBP纹理直方图 fig, ((ax1, ax2, ax3), (ax4, ax5, ax6)) = plt.subplots(nrows=2, ncols=3, figsize=(9, 6)) plt.gray() ax1.imshow(brick) ax1.axis('off') hist(ax4, refs['brick']) ax4.set_ylabel('Percentage') ax2.imshow(grass) ax2.axis('off') hist(ax5, refs['grass']) ax5.set_xlabel('Uniform LBP values') ax3.imshow(wall) ax3.axis('off') hist(ax6, refs['wall']) plt.show() ``` </details> *** ## Shape > 形状特征的表示方法可以分为两类: > > 一是基于轮廓特征,典型方法是傅里叶描述符方法; > > 二是基于区域特征,典型方法是形状无关矩方法。 > > 轮廓特征中只用到物体的边界,而区域特征则需要考虑到整个形状区域。下文将详细介绍这两类方法,另外也会简要介绍一些简单形状特征。 ### 基于轮廓特征 傅里叶描述子 > 参考: > > \[11] 基于傅里叶描述子的物体形状识别的研究 > > \[12] [https://blog.csdn.net/Lemon\_jay/article/details/89349006](https://blog.csdn.net/Lemon\_jay/article/details/89349006) 我的理解是,其实有了很多的备选的边界,然后精髓是把图像的 xy 轴当成实轴虚轴,进行傅里叶变换,取前几项进行近似(这样就平滑了)  <details> <summary>Code</summary> ```python import numpy as np import matplotlib.pyplot as plt from skimage import measure # 构建测试数据 x, y = np.ogrid[-np.pi:np.pi:100j, -np.pi:np.pi:100j] r = np.sin(np.exp((np.sin(x)**3 + np.cos(y)**2))) # 找出轮廓边界 contours = measure.find_contours(r, 0.8) # 显示对应边界 fig, ax = plt.subplots() ax.imshow(r, interpolation='nearest', cmap=plt.cm.gray) for n, contour in enumerate(contours): ax.plot(contour[:, 1], contour[:, 0], linewidth=2) ax.axis('image') ax.set_xticks([]) ax.set_yticks([]) plt.show() # 提取傅里叶形状描述符 contour_array = contour contour_complex = np.empty(contour_array.shape[:-1], dtype=complex) contour_complex.real = contour_array[:, 0] contour_complex.imag = contour_array[:, 1] fourier_result = np.fft.fft(contour_complex) print(fourier_result.shape) ``` </details> ### 基于区域特征 图像区域的某些矩对于平移、旋转、尺度等几何变换具有一些不变的特性 预先准备 1. (j+k)阶矩:$$M _ { j k } = \int \int x ^ { j } y ^ { k } f ( x , y ) d x d y \quad j , k = 0 , 1 , 2 , \cdots  <details> <summary>Code</summary> ```python import matplotlib.pyplot as plt import numpy as np from scipy import ndimage as ndi from skimage import data from skimage.filters import gabor_kernel def compute_feats(image, kernels): feats = np.zeros((len(kernels), 2), dtype=np.double) for k, kernel in enumerate(kernels): filtered = ndi.convolve(image, kernel, mode='wrap') feats[k, 0] = filtered.mean() feats[k, 1] = filtered.var() return feats def match(feats, ref_feats): min_error = np.inf min_i = None for i in range(ref_feats.shape[0]): error = np.sum((feats - ref_feats[i, :])**2) if error < min_error: min_error = error min_i = i return min_i # 准备Gabor卷积核 kernels = [] for theta in range(4): theta = theta / 4. * np.pi for sigma in (1, 3): for frequency in (0.05, 0.25): kernel = np.real(gabor_kernel(frequency, theta=theta,sigma_x=sigma, sigma_y=sigma)) kernels.append(kernel) shrink = (slice(0, None, 3), slice(0, None, 3)) brick = data.brick().astype(np.float64) grass = data.grass().astype(np.float64) checkerboard = data.checkerboard().astype(np.float64) # brick = data.load('brick.png')[shrink] # grass = img_as_float(data.load('grass.png'))[shrink] # wall = img_as_float(data.load('rough-wall.png'))[shrink] # image_names = ('砖块', '草地', '墙壁') image_names = ('brick','grass','checkerboard') # images = (brick, grass, wall) images = [brick, grass, checkerboard] # 准备参考特征 ref_feats = np.zeros((3, len(kernels), 2), dtype=np.double) ref_feats[0, :, :] = compute_feats(brick, kernels) ref_feats[1, :, :] = compute_feats(grass, kernels) ref_feats[2, :, :] = compute_feats(checkerboard, kernels) def power(image, kernel): # Normalize images for better comparison. 05 image = (image - image.mean()) / image.std() return np.sqrt(ndi.convolve(image, np.real(kernel), mode='wrap')**2 +ndi.convolve(image, np.imag(kernel), mode='wrap')**2) # Plot a selection of the filter bank kernels and their responses. results = [] kernel_params = [] for theta in (0, 1): theta = theta / 4. * np.pi for frequency in (0.1, 0.4): kernel = gabor_kernel(frequency, theta=theta) params = 'theta=%d,\nfrequency=%.2f' % (theta * 180 / np.pi, frequency) kernel_params.append(params) # Save kernel and the power image for each image results.append((kernel, [power(img, kernel) for img in images])) fig, axes = plt.subplots(nrows=5, ncols=4, figsize=(5, 6)) plt.gray() fig.suptitle('Image responses for Gabor filter kernels', fontsize=12) axes[0][0].axis('off') # Plot original images for label, img, ax in zip(image_names, images, axes[0][1:]): ax.imshow(img) ax.set_title(label, fontsize=9) ax.axis('off') for label, (kernel, powers), ax_row in zip(kernel_params, results, axes[1:]): # Plot Gabor kernel ax = ax_row[0] ax.imshow(np.real(kernel), interpolation='nearest') ax.set_xlabel(label, fontsize=7) ax.set_xticks([]) ax.set_yticks([]) # Plot Gabor responses with the contrast normalized for each filter vmin = min([np.min(item) for item in powers]) vmax = max([np.max(item) for item in powers]) for patch, ax in zip(powers, ax_row[1:]): ax.imshow(patch, vmin=vmin, vmax=vmax) ax.axis('off') plt.show() ``` </details> ### 局部二值模式 (Local Binary Pattern, BLP) {% hint style="info" %} 通过中心像素与相邻像素的亮度区别,体现出了亮度变换,也就是梯度。 {% endhint %} 基本的LBP算子:3×3的矩形块,有1个中心像素和8个邻域像素分别对应9个灰度值。以中心像素的灰度值为阈值,将其邻域的8个灰度值与阈值比较,大于中心灰度值的像素用1表示,反之用0表示。 根据顺时针方向读出8个二进制值。每个位置有自己的权重。求出这个 3 x 3 的块的值。(下图 为 25) [10] 因为人类视觉系统对纹理的感知与平均灰度(亮度)无关,而局部二值模式方法注重像素灰度的变化,所以它符合人类视觉对图像纹理的感知特点。LBP计算过程如图5-6所示。    <details> <summary>Code</summary> ```python """ 基于二值模式的图像纹理分类 """ import numpy as np import matplotlib.pyplot as plt METHOD = 'uniform' # plt.rcParams['font.size'] = 9 def plot_circle(ax, center, radius, color): circle = plt.Circle(center, radius, facecolor=color,edgecolor='0.5') ax.add_patch(circle) def plot_lbp_model(ax, binary_values): """LBP 方法模型绘制.""" # Geometry spec theta = np.deg2rad(45) R = 1 r = 0.15 w = 1.5 gray = '0.5' # Draw the central pixel. plot_circle(ax, (0, 0), radius=r, color=gray) # Draw the surrounding pixels. for i, facecolor in enumerate(binary_values): x = R * np.cos(i * theta) y = R * np.sin(i * theta) plot_circle(ax, (x, y), radius=r, color=str(facecolor)) # Draw the pixel grid. for x in np.linspace(-w, w, 4): ax.axvline(x, color=gray) ax.axhline(x, color=gray) # Tweak the layout. ax.axis('image') ax.axis('off') size = w + 0.2 ax.set_xlim(-size, size) ax.set_ylim(-size, size) fig, axes = plt.subplots(ncols=5, figsize=(7, 2)) titles = ['flat', 'flat', 'edge', 'corner', 'non-uniform'] binary_patterns = [np.zeros(8), np.ones(8), np.hstack([np.ones(4), np.zeros(4)]), np.hstack([np.zeros(3), np.ones(5)]), [1, 0, 0, 1, 1, 1, 0, 0]] for ax, values, name in zip(axes, binary_patterns, titles): plot_lbp_model(ax, values) ax.set_title(name) #二值模式特征提取部分 from skimage.transform import rotate from skimage.feature import local_binary_pattern from skimage import data from skimage.color import label2rgb # settings for LBP radius = 3 n_points = 8 * radius def overlay_labels(image, lbp, labels): mask = np.logical_or.reduce([lbp == each for each in labels]) return label2rgb(mask, image=image, bg_label=0, alpha=0.5) def highlight_bars(bars, indexes): for i in indexes: bars[i].set_facecolor('r') image = data.brick() lbp = local_binary_pattern(image, n_points, radius, METHOD) def hist(ax, lbp): n_bins = int(lbp.max() + 1) return ax.hist(lbp.ravel(), bins=n_bins, range= (0, n_bins), facecolor='0.5')# normed=True, # 绘制LBP直方图 fig, (ax_img, ax_hist) = plt.subplots(nrows=2, ncols=3, figsize=(9, 6)) plt.gray() titles = ('edge', 'flat', 'corner') w = width = radius - 1 edge_labels = range(n_points // 2 - w, n_points // 2 + w + 1) flat_labels = list(range(0, w + 1)) + list(range(n_points - w, n_points + 2)) i_14 = n_points // 4 # 1/4th of the histogram i_34 = 3 * (n_points // 4) # 3/4th of the histogram corner_labels = (list(range(i_14 - w, i_14 + w + 1)) + list(range(i_34 - w, i_34 + w + 1))) label_sets = (edge_labels, flat_labels, corner_labels) for ax, labels in zip(ax_img, label_sets): ax.imshow(overlay_labels(image, lbp, labels)) for ax, labels, name in zip(ax_hist, label_sets, titles): counts, _, bars = hist(ax, lbp) highlight_bars(bars, labels) ax.set_ylim(top=np.max(counts[:-1])) ax.set_xlim(right=n_points + 2) ax.set_title(name) ax_hist[0].set_ylabel('Percentage') for ax in ax_img: ax.axis('off') #使用LBP对图像纹理进行分类 radius = 2 n_points = 8 * radius def kullback_leibler_divergence(p, q): p = np.asarray(p) q = np.asarray(q) filt = np.logical_and(p != 0, q != 0) return np.sum(p[filt] * np.log2(p[filt] / q[filt])) def match(refs, img): best_score = 10 best_name = None lbp = local_binary_pattern(img, n_points, radius, METHOD) n_bins = int(lbp.max() + 1) hist, _ = np.histogram(lbp, density=True, bins=n_bins, range= (0, n_bins)) for name, ref in refs.items(): ref_hist, _ = np.histogram(ref, density=True, bins=n_bins, range=(0, n_bins)) score = kullback_leibler_divergence(hist, ref_hist) if score < best_score: best_score = score best_name = name return best_name brick = data.brick() grass = data.grass() wall = data.gravel() refs = { 'brick': local_binary_pattern(brick, n_points, radius, METHOD), 'grass': local_binary_pattern(grass, n_points, radius, METHOD), 'wall': local_binary_pattern(wall, n_points, radius, METHOD) } # 对特征进行分类 print('Rotated images matched against references using LBP:') print('original: brick, rotated: 30deg, match result: ', match(refs, rotate(brick, angle=30, resize=False))) print('original: brick, rotated: 70deg, match result: ', match(refs, rotate(brick, angle=70, resize=False))) print('original: grass, rotated: 145deg, match result: ', match(refs, rotate(grass, angle=145, resize=False))) # 绘制LBP纹理直方图 fig, ((ax1, ax2, ax3), (ax4, ax5, ax6)) = plt.subplots(nrows=2, ncols=3, figsize=(9, 6)) plt.gray() ax1.imshow(brick) ax1.axis('off') hist(ax4, refs['brick']) ax4.set_ylabel('Percentage') ax2.imshow(grass) ax2.axis('off') hist(ax5, refs['grass']) ax5.set_xlabel('Uniform LBP values') ax3.imshow(wall) ax3.axis('off') hist(ax6, refs['wall']) plt.show() ``` </details> *** ## Shape > 形状特征的表示方法可以分为两类: > > 一是基于轮廓特征,典型方法是傅里叶描述符方法; > > 二是基于区域特征,典型方法是形状无关矩方法。 > > 轮廓特征中只用到物体的边界,而区域特征则需要考虑到整个形状区域。下文将详细介绍这两类方法,另外也会简要介绍一些简单形状特征。 ### 基于轮廓特征 傅里叶描述子 > 参考: > > \[11] 基于傅里叶描述子的物体形状识别的研究 > > \[12] [https://blog.csdn.net/Lemon\_jay/article/details/89349006](https://blog.csdn.net/Lemon\_jay/article/details/89349006) 我的理解是,其实有了很多的备选的边界,然后精髓是把图像的 xy 轴当成实轴虚轴,进行傅里叶变换,取前几项进行近似(这样就平滑了)  <details> <summary>Code</summary> ```python import numpy as np import matplotlib.pyplot as plt from skimage import measure # 构建测试数据 x, y = np.ogrid[-np.pi:np.pi:100j, -np.pi:np.pi:100j] r = np.sin(np.exp((np.sin(x)**3 + np.cos(y)**2))) # 找出轮廓边界 contours = measure.find_contours(r, 0.8) # 显示对应边界 fig, ax = plt.subplots() ax.imshow(r, interpolation='nearest', cmap=plt.cm.gray) for n, contour in enumerate(contours): ax.plot(contour[:, 1], contour[:, 0], linewidth=2) ax.axis('image') ax.set_xticks([]) ax.set_yticks([]) plt.show() # 提取傅里叶形状描述符 contour_array = contour contour_complex = np.empty(contour_array.shape[:-1], dtype=complex) contour_complex.real = contour_array[:, 0] contour_complex.imag = contour_array[:, 1] fourier_result = np.fft.fft(contour_complex) print(fourier_result.shape) ``` </details> ### 基于区域特征 图像区域的某些矩对于平移、旋转、尺度等几何变换具有一些不变的特性 预先准备 1. (j+k)阶矩:$$M _ { j k } = \int \int x ^ { j } y ^ { k } f ( x , y ) d x d y \quad j , k = 0 , 1 , 2 , \cdots
为了描述物体的形状,假设f(x,y)的目标物体取值为1,背景为0:$$M_{00}=\sum_{x=1}^N\sum_{y=1}^M f(x,y)$$
质心坐标与中心距
当j=1,k=0时,$$M_{10}$$对二值图像来讲就是物体上所有点的x坐标的总和
类似,$$M_{01}$$就是物体上所有点的y坐标的总和
所以 $$\bar{x}=\frac{M_{10}}{M_{00}}$$, $$\bar{y}=\frac{M_{01}}{M_{00}}$$就是二值图像中一个物体的质心坐标 。
为了获得矩的不变特征,往往采用中心矩以及归一化的中心距 。 ($$\overline{x}$$,$$\overline{y}$$是物体的质心。中心矩以质心作为原点进行计算,因此它具有位置无关性。)
M j k ′ = ∑ x = 1 N ∑ y = 1 M ( x − x ― ) j ( y − y ― ) k f ( x , y ) 主轴
使二阶中心距变得最小的旋转角$$\theta$$:
tan 2 θ = 2 μ 11 μ 20 − μ 02 将x、y轴分别旋转$$\theta$$角得坐标轴x和y',x'、y称为该物体的主轴。如果物体在计算矩之前旋转$$\theta$$角,或相对于x', y轴计算短,那么计算后得出的矩具有旋转不变性。
Edge
space-transform.md
一阶边缘检测
Robert
Sobel
Prewitt
二阶边缘检测
Laplace
LoG = Gaussian + Laplace = 平滑 + 边缘
Point
一是基于模板的角点检测算法;二是基于边缘的角点检测算法;三是基于图像灰度变化的角点检测算法
SUSAN算法:
SUSAN以及后续研究:[13] https://core.ac.uk/download/41438484.pdf
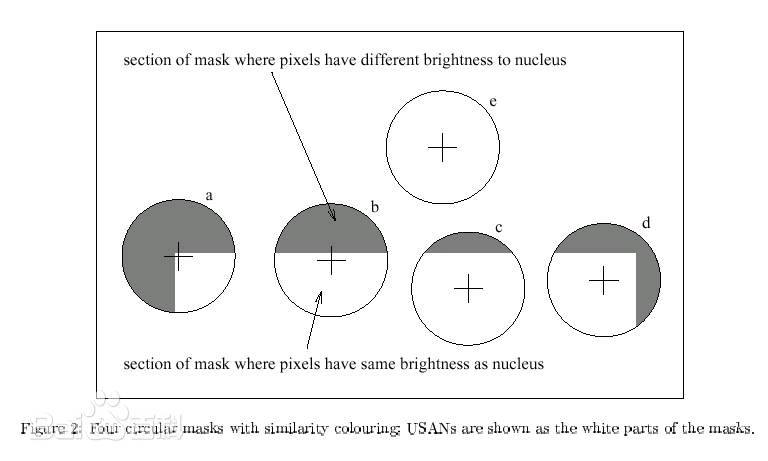
用圆形模板,根据亮度值是否相似于核心点亮度的,把区域分成核值相似区USAN与核值不相似区
模板在图像上移动时
当圆形模板完全在背景或者目标区域时 ,其 USAN区域最大
当核心在边缘时 , USAN 区域减少一半
当核心在角点时 , USAN 区域最小
可以通过计算每 1 个像素的 USAN 值,并与设定的门限值进行比较, 如果该像素的 USAN 值小于门限 值,则该点可以认为是 1 个边缘点
https://baike.baidu.com/item/susan%E7%AE%97%E5%AD%90/5532045
Reference
[1] https://blog.51cto.com/u_13984132/5477443
[2] https://hal.science/hal-02126655v1/file/Texture_Feature_Extraction_Methods_A_Survey.pdf
[3] https://github.com/cgreen259/Texture-Toolbox
[4] M. Petrou and P. G. Sevilla, Image Processing: Dealing With Texture, vol. 1. Chichester, U.K.: Wiley, 2006.
[5] https://medium.com/@krzysztofdrelczuk/acf-autocorrelation-function-simple-explanation-with-python-example-492484c32711
[6] M. Sharma and H. Ghosh, ‘‘Histogram of gradient magnitudes: A rotation invariant texture-descriptor,’’ in Proc. IEEE Int. Conf. Image Process. (ICIP), Sep. 2015, pp. 4614–4618.
[7] http://matlab.izmiran.ru/help/toolbox/images/enhanc15.html
[8] https://ojskrede.github.io/inf4300/notes/week_02/
[9] https://courses.cs.washington.edu/courses/cse576/book/ch7.pdf
[10] https://aihalapathirana.medium.com/understanding-the-local-binary-pattern-lbp-a-powerful-method-for-texture-analysis-in-computer-4fb55b3ed8b8
[11] https://www.doc88.com/p-7176387138708.html
[12] https://blog.csdn.net/Lemon_jay/article/details/89349006
[13] https://core.ac.uk/download/41438484.pdf
[14] https://baike.baidu.com/item/susan%E7%AE%97%E5%AD%90/5532045
 [14] https://baike.baidu.com/item/susan%E7%AE%97%E5%AD%90/5532045